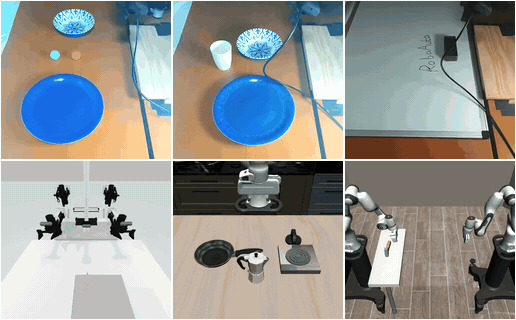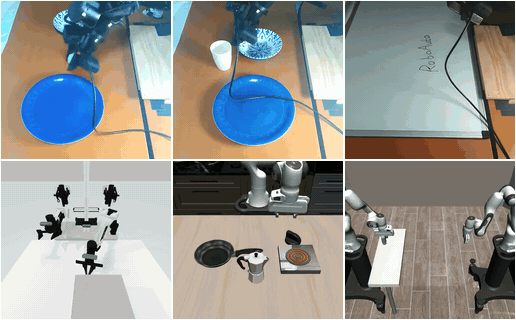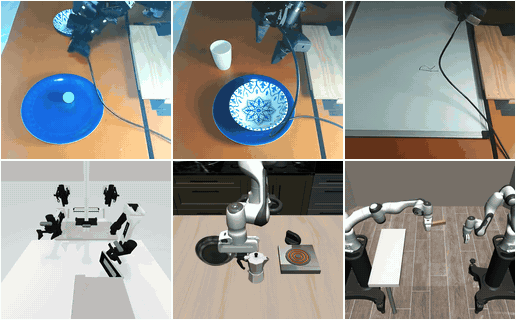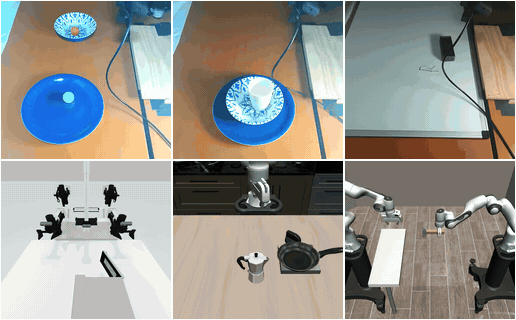
RoboAuto: Autonomous Robot Program Search through Multi-Level Physical Understanding.
Coding agents write and debug robot programs but do not understand the physical world. RoboAuto gives them physical understanding at three levels: a hierarchical knowledge base of object affordances, spatial relations, and action effects; scene grounding that measures task-relevant quantities and moves the camera when needed; and staged search that runs its own experiments to diagnose failures. RoboAuto outperforms prior methods on tasks from LIBERO-PRO, LIBERO-PRO Long, LIBERO-Plus, and Robosuite and on three long-horizon real-robot tasks. Its knowledge also transfers to RoboTwin 2.0 tasks on a bimanual robot.